
Automated Lab Workcell
Overview
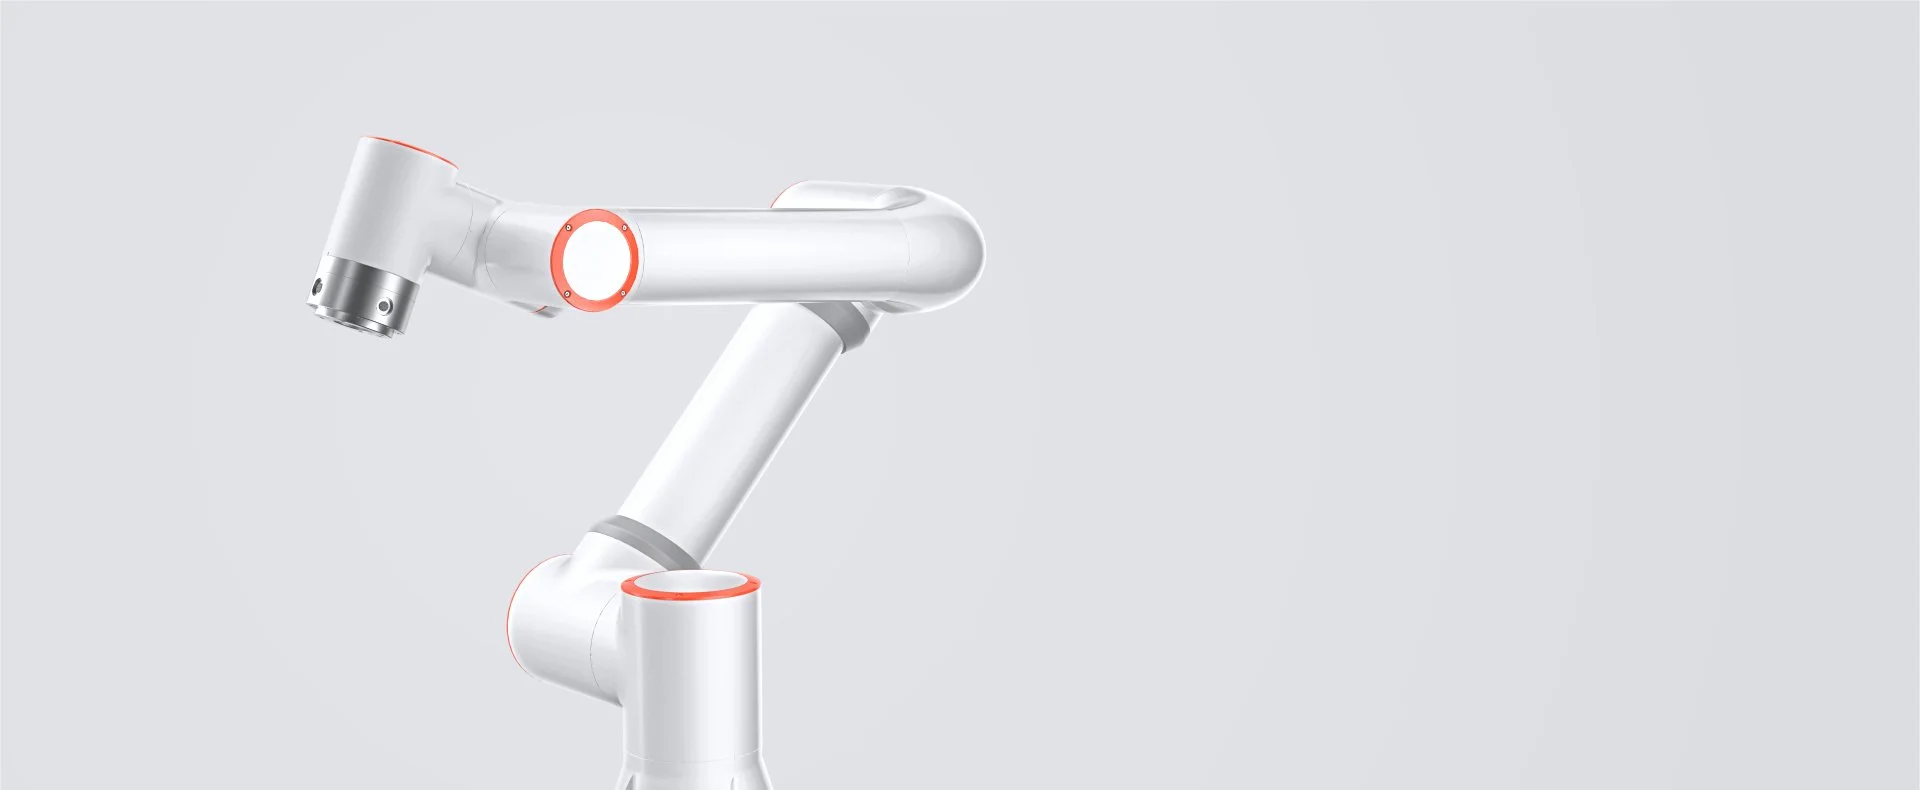
At Myriad I co-led the end-to-end integration of a collaborative robotic workcell to automate batch microplate labeling. Working closely with lab users, I shadowed daily workflows to establish core requirements around throughput, footprint, and collaborative safety. I drove the 6-axis cobot lifecycle from research and vendor negotiation through CAD design to full physical assembly. On the integration side, I configured serial-to-ethernet servers, established communication to labeler and barcode scanning instruments, and spun up instrument drivers. The deployed workcell turned a manual lab process into an automated system that boosted operational efficiency, reduced operator touch time, and demonstrated the Hardware Automation Team’s capability to deliver future workcells.
Role
Hardware Automation Engineer
Project Co-Lead
Timeline
6 months
Tools + Skills
Robotic Arm: 6-axis Cobot Research, Selection, Mounting + Rigid Fixturing, End-of-Arm Tooling (EOAT), Fingered Gripper Design, Motion Trajectory Teaching, Workcell Layout + Integration
Control Systems + Automation: Robot + Instrument Integration, I/O Systems, Sensor Integration, Computer Networking (Ethernet/IP Architecture), Nport Serial-to-Ethernet Server Integration, Instrument Driver Spin-up, Automated Scheduler Handoff
Hardware Design & Manufacturing: Onshape (3D Modeling, Assemblies, GD&T Drawings), FDM 3D Printing
Process: User Shadowing + Workflow Analysis, System/Component Requirements, Budget Tracking + Allocation, Design Reviews, Design Verification Testing (DVT), Lab Staff Training, Preventative Maintenance (PM) Development, Support Handoff
Safety: Robot Risk Assessment, Ergonomic Assessment, Safety Zone Configuration, E-Stop Integration
Documentation: Design Journals, Troubleshooting + Maintenance Guides, Bill of Materials (BOM), Arena Product Lifecycle Management (PLM), Work Instructions, Github Repository Control
This project is a work in progress
Check out my other projects in the meantime!